Android Mobile ENGINEER
Artsiom Seliuzhytski
Category: Embedded
-
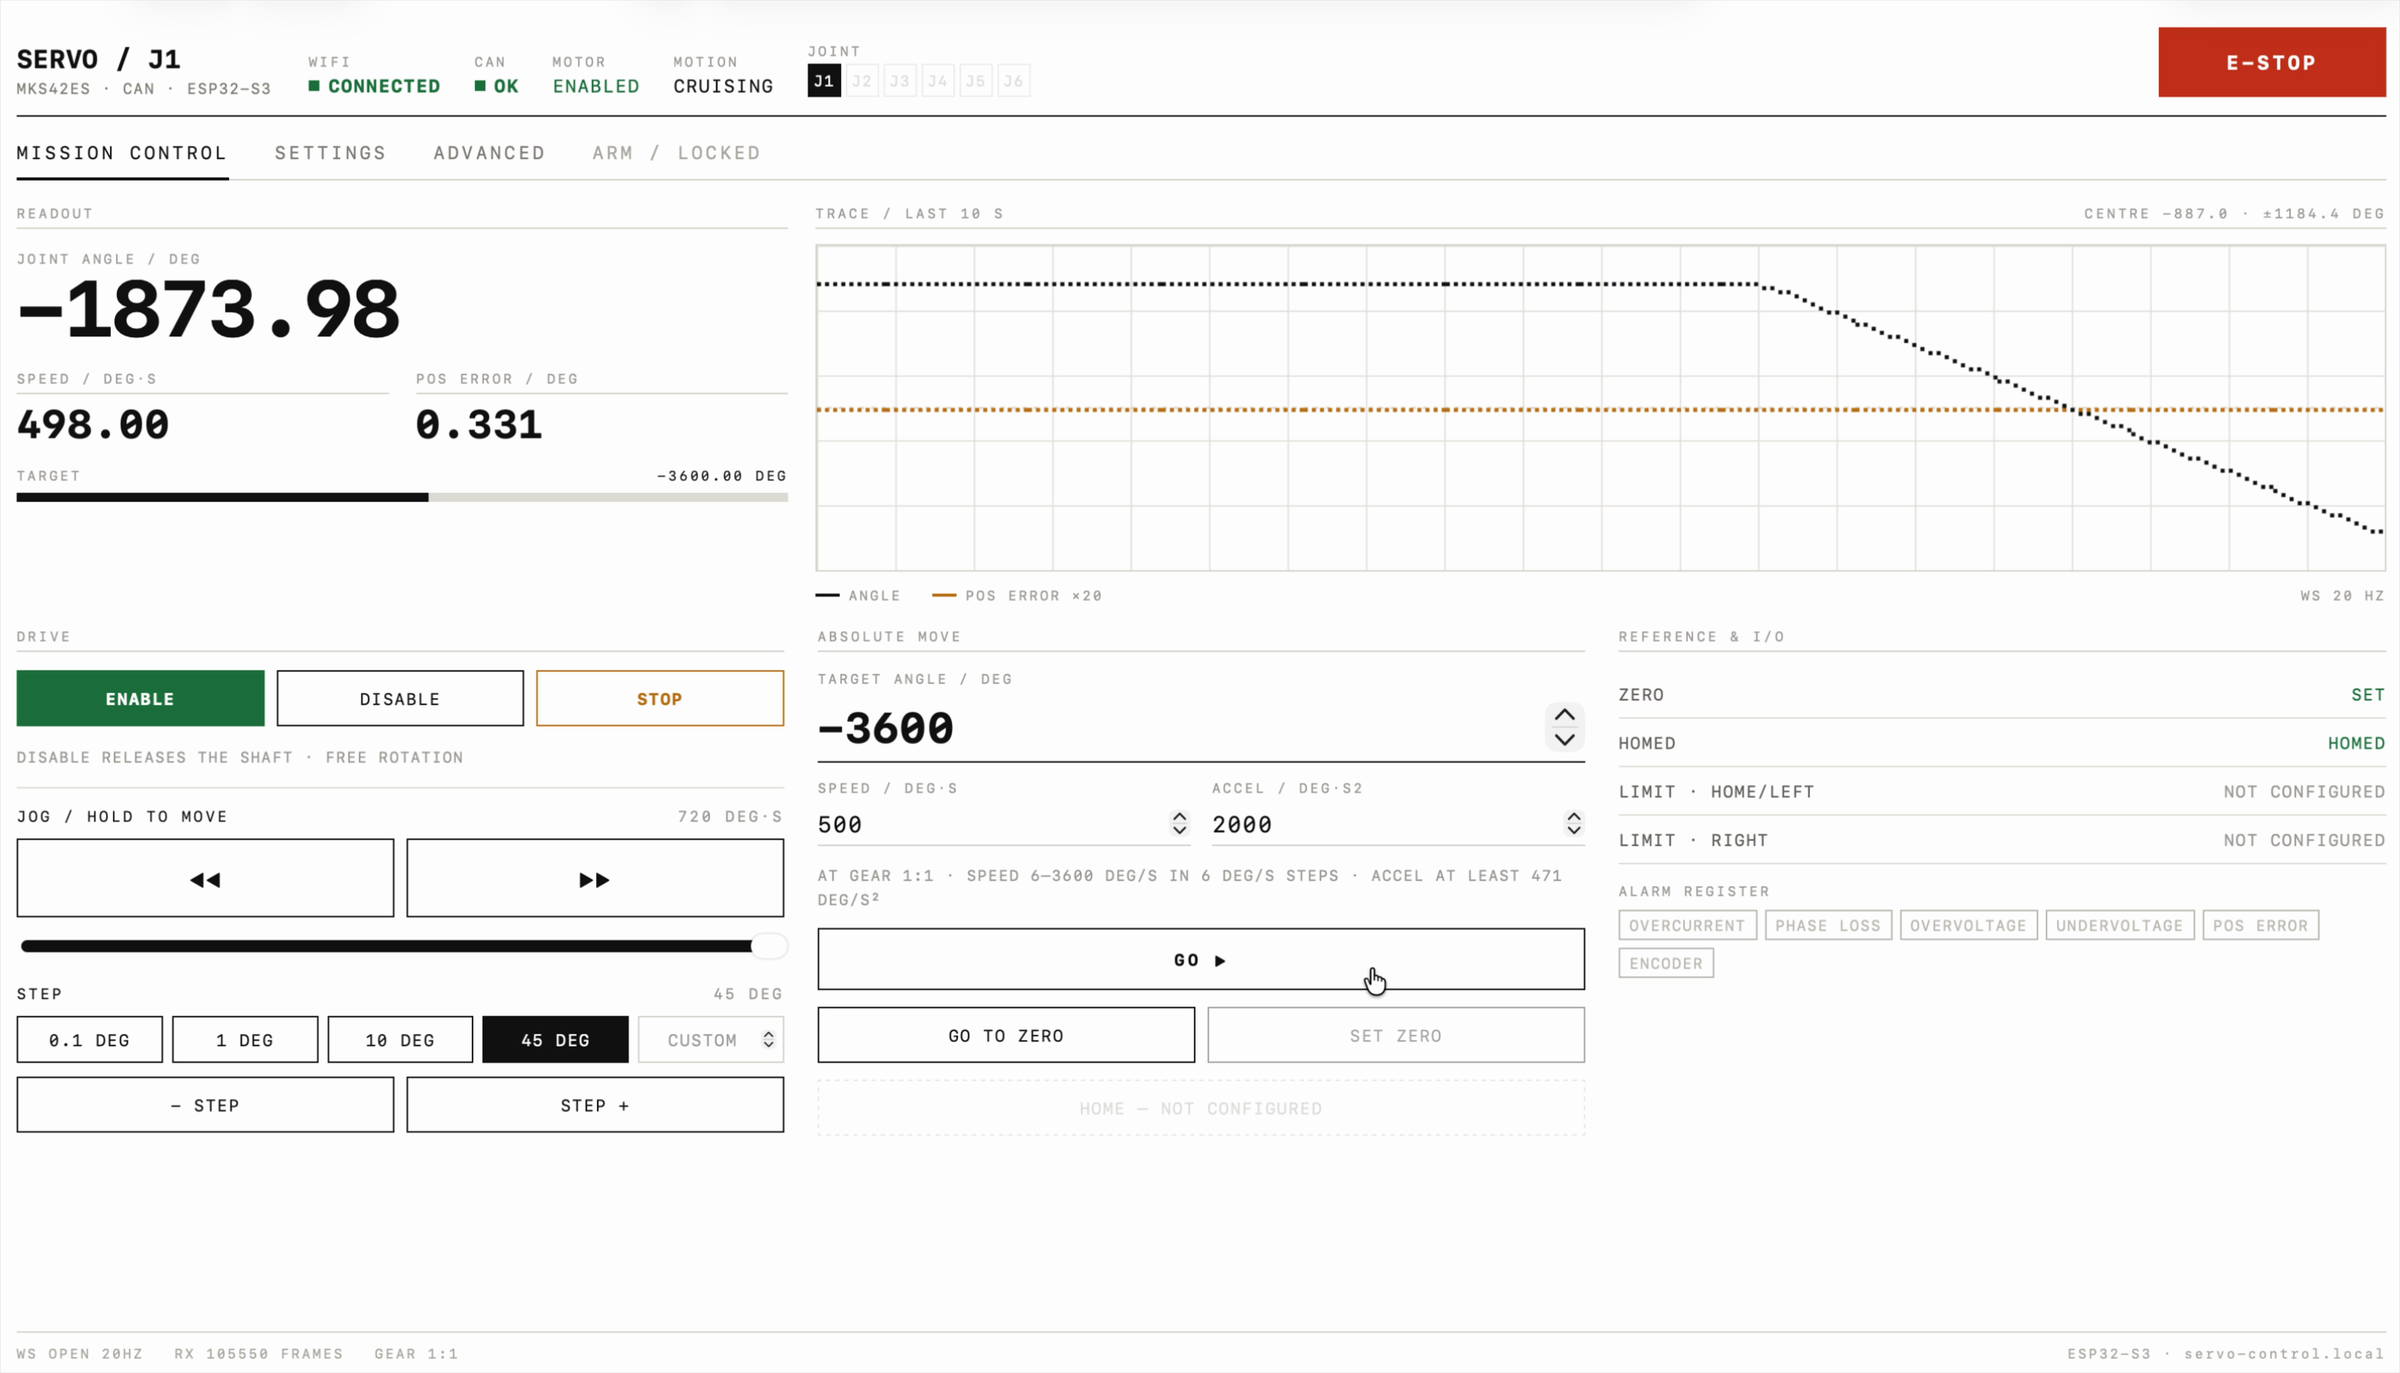
I want to build a six axis robotic arm, and every joint needs a motor I can position precisely and read back. I picked the MKS SERVO42ES: a NEMA17 stepper with a closed loop driver on the back, a magnetic encoder, FOC control and a CAN port, so all six joints can share one bus.…